Robotics Programming is the work of turning sensor data and human intent into safe, repeatable machine behavior—and the hard part is rarely the syntax. The fastest route in 2026 is to learn the software stack in layers: use Python for fast behavior and perception work, C++ when timing and hardware control matter, ROS 2 to connect components, and vendor tools when the robot controller requires them.
That answer is more useful than the usual “learn Python first” shortcut because a robot is not a web app with wheels. Code has to survive noisy sensors, delayed messages, mechanical limits, calibration error, power loss, changing payloads, and the possibility that a bad command moves real mass. The same program that looks perfect in simulation can fail on hardware because the physical system never matches the model exactly.
The market context makes that distinction increasingly important. The International Federation of Robotics reported 542,000 industrial robots installed in 2024 and 4.664 million units operating worldwide, while Open Robotics reported nearly 984 million ROS package downloads in 2025. Those numbers do not mean every robot runs ROS, but they show why software architecture, integration, and maintainability now matter alongside motion code.
I reviewed ten prominent current pages for this keyword before drafting. Most do a good job explaining Python, C++, Arduino-style platforms, ROS, sensors, and beginner projects. The recurring gap is decision depth: which layer you are programming, what timing or safety constraint applies, what changes when you move from simulation to hardware, and when a proprietary industrial language enters the picture. This guide is built around those decisions, so you can choose a learning path that still makes sense after your first demo works.
What Does Robotics Programming Actually Control?
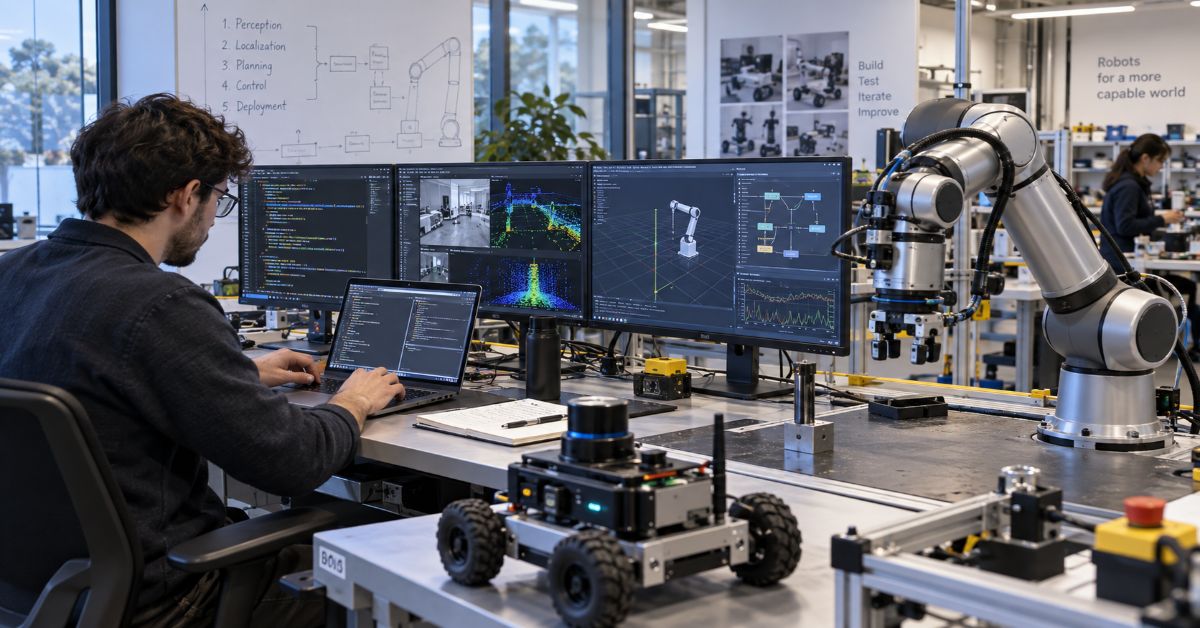
A robot program closes a loop between sensing and action. Sensors measure the world or the robot itself; software interprets that information; a planner or state machine chooses a response; controllers turn that response into actuator commands; and feedback checks whether the machine did what was expected. The loop can run once every few seconds for a warehouse task decision or many times per second for motion control. Those are different programming problems even when they live on the same robot.
I find it more useful to think in layers than in languages. A camera node, navigation planner, motor controller, safety-rated stop, and factory PLC may all be involved in one application, but they do not share the same latency budget, failure modes, or toolchain. That is why a production robot often uses several languages and interfaces at once.
The stack matters because each layer rewards a different kind of code. This table shows the practical split.
| Layer | Typical job | Common tools/languages | Main failure to watch |
| Task / behavior | Choose goals, sequence work, handle states | Python, C++, behavior trees, vendor APIs | Logic works in the happy path but has no recovery state |
| Perception / AI | Turn camera, LiDAR, force, or audio data into useful signals | Python/C++, OpenCV, ML frameworks, Isaac ROS | Latency or false detections destabilize downstream behavior |
| Middleware | Move typed data between components | ROS 2, DDS/RMW, services, actions, topics | QoS, discovery, namespace, or version mismatch |
| Control | Convert targets into stable motion | C++, controller SDKs, ros2_control, PLC/real-time tools | Jitter, missed deadlines, unstable gains, saturation |
| Controller / cell | Execute robot moves, I/O, interlocks, tooling | RAPID, KRL, URScript, TP/KAREL, INFORM, PLC languages | Vendor lock-in, frame errors, unsafe I/O assumptions |
Which Programming Language Should You Learn First?
For most beginners building a simulated mobile robot, a small vision project, or a research prototype, Python is the shortest path to useful feedback. Its syntax is readable, robotics libraries are plentiful, and ROS 2 supports Python through rclpy. I would not treat that as a claim that Python is the universal robotics language. It is a good first interface to the system, not a replacement for understanding the system.
When does C++ become important?
C++ becomes more attractive when you need tighter control over latency, memory, drivers, high-throughput perception, or lower-level robotics libraries. ROS 2 supports both Python and C++, so a common architecture is to keep orchestration or experimentation in Python while moving performance-sensitive components to C++. The 2026 Lyrical release also improves Python-side capability with an AsyncNode for asyncio and introduces executor changes that Open Robotics says can reduce CPU use, which makes the boundary more nuanced than old “Python is slow, C++ is fast” slogans.
Why industrial robots add another language layer
If your goal is factory automation, learn the robot you actually expect to touch. ABB uses RAPID, KUKA uses KRL, Universal Robots exposes URScript, FANUC environments use TP and KAREL, and Yaskawa uses INFORM. A Python vision service can still feed those cells through an API, fieldbus, PLC, or middleware bridge, but the controller-side motion program may remain vendor-specific. That is a hidden portability cost that many beginner language lists understate.
There is no single winner. Match the language to the layer and the robot you expect to use.
| Choice | Start here when | Strength | Trade-off |
| Python | You are learning logic, perception, data handling, or ROS 2 basics | Fast iteration and readable code | Not the default answer for every real-time or controller-level task |
| C++ | You need performance, hardware interfaces, or deeper ROS 2 work | Control over memory and execution; mature robotics libraries | More build-system and language complexity |
| Vendor robot language | You work directly on an industrial controller | Native motion, I/O, frames, and OEM support | Skills and code may not transfer cleanly between brands |
| Block / graphical tools | You need a low-friction first exposure or teach-pendant workflow | Immediate feedback with little syntax overhead | Can hide concepts you eventually need to debug |
| PLC languages | You are integrating a robot cell with industrial automation | Strong fit for cell sequencing, I/O, interlocks, and plant controls | Different mental model from application software |
Why ROS 2 Matters in Modern Robotics Programming
ROS 2 is not a programming language. It is an open-source set of libraries, tools, conventions, and middleware interfaces that let robot components communicate without collapsing everything into one executable. A Python node can publish perception data, a C++ node can consume it for planning, and another controller can expose hardware through a standard interface. That separation is valuable when sensors, robots, or algorithms change.
The current release context is important. Open Robotics released ROS 2 Lyrical Luth on May 22, 2026 as a long-term-support distribution supported until May 2031. The project also reported that ROS 2 accounted for 91.2% of ROS downloads in its 2025 metrics. For a new learner in 2026, that makes current ROS 2 documentation a better default than old ROS 1 tutorials or stale setup guides. I would start with the official Lyrical installation and beginner tutorials rather than copying commands from an undated blog post (Open Robotics, 2026).
That freshness habit transfers beyond robotics. Rubble Magazine’s OpenClaw GitHub guide on verifying the canonical repository and current prerequisites makes the same engineering point: source identity and version context are part of correct setup, not administrative detail.
How Should You Learn: Simulation First or Hardware First?
Start in simulation when the behavior can move hardware fast enough to damage itself, nearby equipment, or a person. Simulation lets you inspect coordinate frames, trajectories, collisions, sensor streams, and state transitions without paying for every mistake. Gazebo is tightly connected to the ROS ecosystem, while other simulators and vendor environments may fit reinforcement learning, industrial offline programming, or a specific robot family better.
But simulation is not proof of real-world readiness. The model may use ideal friction, perfect timestamps, simplified cables, exact dimensions, clean lighting, and a payload that never shifts. The useful discipline is sim-to-hardware staging: validate logic in simulation, replay recorded sensor data, constrain speed and force, test one subsystem at a time, and log what changes on the real robot. Calibration is not cleanup work after programming. It is part of programming a physical system.
A practical first project
A strong first project is deliberately small: make a simulated differential-drive robot move toward a waypoint, stop when an obstacle enters a threshold, publish its state, and recover when the obstacle clears. That single exercise forces you to touch sensing, messages, state logic, motion commands, logging, and failure handling. Add computer vision only after the basic loop is reliable.
If you later introduce learned perception or policy models, Rubble Magazine’s guide to machine learning models is a useful reminder to match the model to latency, data, error cost, and deployment constraints rather than choosing the most fashionable architecture.
An Eight-Week Beginner Roadmap That Builds Transferable Skills
I would structure the first two months around increasingly complete loops, not around collecting languages. The target is a small portfolio of systems you can explain, reproduce, and debug. If you are switching careers rather than adding robotics to an existing role, the same evidence-first approach works well with a staged transition plan instead of an all-or-nothing leap.
For readers making that broader transition, Rubble Magazine’s low-risk 90-day career-change plan offers a useful way to separate skill-building, proof of work, and decision gates.
The sequence below keeps every week tied to a demonstrable engineering outcome.
| Weeks | Build | What you should be able to explain |
| 1–2 | Python basics, Linux shell, Git, simple sensor or simulated input | Variables, functions, packages, logs, units, coordinate assumptions |
| 3–4 | ROS 2 nodes, topics, services/actions, launch, tf2, rosbag | How data moves, where interfaces break, and how to reproduce a run |
| 5–6 | Simulation project with navigation or arm motion | Frames, limits, collision assumptions, controller versus planner roles |
| 7 | Hardware or recorded-data integration at conservative limits | Calibration, timestamps, wiring/power faults, device permissions, recovery |
| 8 | One performance or reliability upgrade | Why you changed a node, dependency, language, QoS setting, or architecture |
What Risks and Trade-Offs Matter Most?
Version drift can break a working robot without changing your code
Robotics stacks cross operating systems, device drivers, firmware, middleware, GPU runtimes, build tools, and vendor SDKs. A dependency update can change a message type, driver behavior, compiler requirement, or hardware interface. Pin versions where reproducibility matters, record firmware alongside software releases, and keep setup scripts under version control. I treat environment reconstruction as a core robotics skill.
The same lesson appears in Rubble Magazine’s JAVE2 version and deployment guide: a small API change can be trivial in source code yet expensive in deployment when native dependencies and platforms are involved.
Safety cannot be delegated to application logic
A normal application node should not be your only protection against hazardous motion. Use the robot manufacturer’s safety functions, physical limits, emergency-stop architecture, rated interlocks, safe speeds, workspace restrictions, and the risk assessment appropriate to the installation. In software, add conservative defaults, command limits, watchdogs, timeouts, and explicit failure states. Simulation helps find logic errors; it does not certify a cell as safe.
AI adds capability, but it also adds a verification problem
Learned perception and policy models can reduce the amount of hand-coded logic needed for some tasks, but they also produce outputs that are harder to reason about than a fixed state machine. I would keep deterministic limits and fallback behavior around model-driven components, log the observations that produced important decisions, and test edge cases that are rare in training data. The model should expand what the robot can do without erasing the boundaries that keep the system understandable.
What Is the Real-World Impact of Better Robot Software?
The software layer matters because robot adoption is already large enough for integration quality to affect real operations. According to IFR’s World Robotics 2025 report, 542,000 industrial robots were installed in 2024, the second-highest annual total the federation had recorded, while 4.664 million industrial robots were in operational use worldwide. IFR president Takayuki Ito linked the long-term rise in deployments to industries moving deeper into digital and automated production (International Federation of Robotics, 2025).
For developers, that creates two distinct opportunities. One is classic automation: reliable motion, tooling, I/O, vision, PLC integration, fleet management, and maintainable upgrades. The other is AI-heavy robotics, where perception, world models, learned policies, and simulation-generated data become part of the stack. NVIDIA Isaac ROS is described as CUDA-accelerated packages and AI models built for ROS 2, which is a good example of these worlds converging rather than one replacing the other (NVIDIA, n.d.).
The Future of Robotics Programming in 2027
The 2027 direction looks less like “AI replaces coding” and more like a shift in where engineers spend their effort. Hand-written code will still define interfaces, limits, device integration, observability, safety boundaries, and deployment. More behavior may be learned, generated, or composed from higher-level tools, especially for perception and manipulation, but the surrounding system still needs deterministic contracts.
There is a concrete roadmap signal: the ROS 2 team has already named the May 2027 release Makoa Mata-mata, and Gazebo maintainers announced a cadence that aligns the next Gazebo release for March 2027. That tighter release coordination should make current tutorials and simulator compatibility more important, not less. Meanwhile, physical-AI research is pushing toward generalist robot models; NVIDIA researcher Jim Fan has described humanoid robots as “the next wave of embodied AI” (Huang, 2024). I read that as a vendor-backed direction, not a guarantee that general-purpose humanoids will replace specialized automation on a fixed timetable.
My practical expectation is that good robotics programmers in 2027 will be judged less by how many languages they know and more by whether they can define interfaces, diagnose timing and frame errors, move between simulation and hardware, evaluate model behavior, and keep a system reproducible across releases. Those skills survive tool changes.
Key Takeaways
- Learn the control stack before collecting languages; each layer has different timing, safety, and integration constraints.
- Use Python for fast feedback when it fits, then introduce C++ or controller-native tools when the system—not fashion—demands them.
- Treat ROS 2 as middleware and interface discipline, not as a language; start with current Lyrical Luth documentation in 2026.
- Run new behavior in simulation first, then stage real-hardware tests with conservative limits, calibration checks, logging, and recovery states.
- Expect industrial robots to involve proprietary controller languages even when perception, planning, or analytics are written in general-purpose languages.
- Pin environments and document firmware, drivers, packages, and build steps because version drift is a robotics failure mode.
- For 2027, expect more learned behavior and physical-AI tooling, but deterministic interfaces, safety boundaries, and reproducibility will remain core engineering work.
Conclusion
Robotics programming becomes much less confusing once you stop treating it as a contest between Python and C++. A robot is a stack of sensing, communication, planning, control, hardware, and safety responsibilities. Your language choice follows the layer you are working in, the timing you need, and the controller you actually have.
For a beginner, I would start small: learn enough Python and Linux to manipulate data and run tools, use current ROS 2 tutorials to understand interfaces, build one complete behavior in simulation, and then move that same behavior onto hardware at conservative limits. Add C++, vendor languages, PLC work, or AI models only when the project gives you a reason.
That approach is slower than chasing impressive demos for a week and much faster than rebuilding a fragile stack three months later. The durable skill is not memorizing commands. It is learning how physical constraints, software interfaces, timing, versions, and failure recovery fit together—and being able to explain why the robot behaves the way it does.
Frequently Asked Questions
Is robot programming hard for beginners?
It can feel difficult because software, electronics, mechanics, and coordinate systems meet in one project. The easiest path is to narrow the scope: learn basic Python, use simulation, then build one sense-decide-act loop. You do not need advanced control theory before your first useful project.
What programming language is best for robotics?
There is no universal best language. Python is practical for learning, orchestration, perception, and prototyping. C++ is common in performance-sensitive and lower-level work. Industrial controllers may require vendor languages such as RAPID, KRL, URScript, TP/KAREL, or INFORM.
Do I need ROS 2 to program robots?
No. Small kits, industrial teach pendants, and vendor SDKs can work without ROS 2. ROS 2 becomes valuable when you need modular components, multiple sensors, replaceable hardware, distributed processes, reusable tooling, or a larger team.
Can I learn robot programming without buying a robot?
Yes. Simulation can teach nodes, messages, coordinate frames, planning, logging, and many debugging habits. Hardware becomes important later because real sensors, calibration, latency, friction, wiring, and safety constraints are difficult to reproduce perfectly in simulation.
Is Python enough for robot programming?
Python can take you far, especially for high-level behavior, perception, data work, and ROS 2 experiments. It is not enough for every robot or every layer. You may eventually need C++, a vendor controller language, PLC programming, or a real-time tool depending on the application.
How is robot programming different from normal software development?
Robot code changes the physical world. That means timing, sensor noise, units, coordinate frames, actuator limits, calibration, watchdogs, and safe recovery matter alongside ordinary software concerns such as APIs, tests, version control, and deployment.
Will AI replace robotics programmers?
AI is more likely to change the work than eliminate the need for it. Learned models can handle perception, planning, or policy generation, but engineers still need to integrate hardware, define interfaces, enforce limits, evaluate failure modes, manage data, and deploy systems reproducibly.
Methodology
I researched this article on September 19, 2026. Before drafting, I reviewed ten prominent current organic pages surfaced for “robotics programming” and close-intent queries: OpenKinematics, Digital Citizen, DevPebble, Petoi, Techpresso Academy, two Bring On The Robots guides, Standard Bots, Industrial Robotics Hub, and DigiSaaSPro. Search rankings vary by country, device, personalization, and time, so I treated them as a competitive sample rather than a permanent universal top ten.
The recurring strengths were beginner definitions, Python/C++ comparisons, ROS introductions, hardware-platform suggestions, and step-by-step first projects. The clearest information gains were current ROS 2 Lyrical context, the stack-by-layer decision model, vendor-specific industrial languages, simulation-to-hardware transfer risk, dependency/version discipline, and bounded 2027 analysis. I built the article around those gaps instead of copying competitor structures.
Technical and adoption claims were validated against Open Robotics documentation and metrics, the International Federation of Robotics, and NVIDIA’s developer/research material. I did not run a controlled robot benchmark or independent safety certification, so I do not claim language-speed numbers, simulator fidelity percentages, or universal deployment outcomes. Vendor tools and releases can change; readers should recheck current documentation before installation or production use.
AI assistance was used in research organization, drafting, and document production. A human editor must review the article before publishing, verify statistics and named claims against the original sources, confirm APA references and live links, and ensure that any first-person wording accurately reflects the human author’s own judgment.
References
- International Federation of Robotics. (2025, September 25). World Robotics 2025 report – INDUSTRIAL ROBOTS – released by IFR: Global robot demand in factories doubles over 10 years.
- NVIDIA. (n.d.). NVIDIA Isaac ROS. Retrieved September 19, 2026.
- Huang, S. (2024, November 6). NVIDIA advances robot learning and humanoid development with new AI and simulation tools. NVIDIA Blog.
- NVIDIA Research. (2025, March 17). NVIDIA Isaac GR00T N1: An open foundation model for humanoid robots.
- Open Robotics. (2026, May 22). ROS 2 Lyrical Luth released.
- Open Robotics. (2026). 2025 ROS Metrics Report. Retrieved September 19, 2026.
- Open Robotics. (2026). ROS 2 Lyrical documentation. Retrieved September 19, 2026.